HK Seymaturbino · Powered by HK-SkillLexR&D DEMO · SAMPLE DATA
01 / 06Field input
 HyperKineticsMANUFACTURING INTELLIGENCE
MANUFACTURING INTELLIGENCE · R&D
Explore four technologies—from object and motion analysis to skill knowledge, manufacturing documents, and robot simulation.
01 / TYCHO R&D
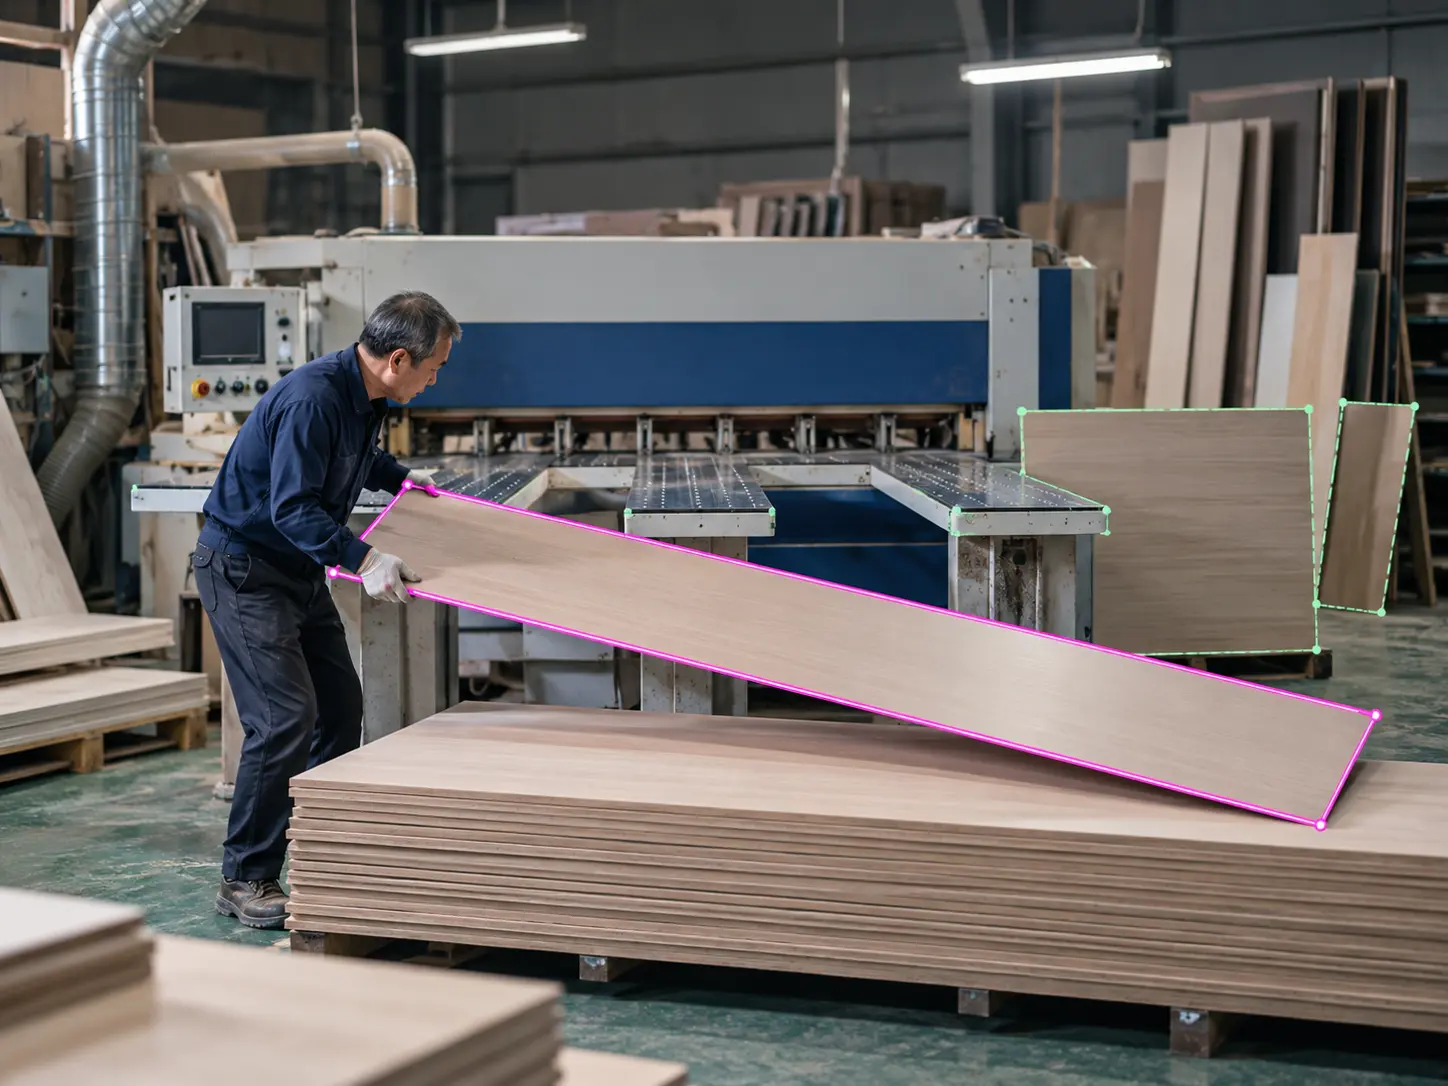
Estimates the bounding box and confidence of the target panel being manipulated. Expert-labeled field data supports training and evaluation of a manufacturing-specific vision model.
In-house domain-specific vision model · Field validation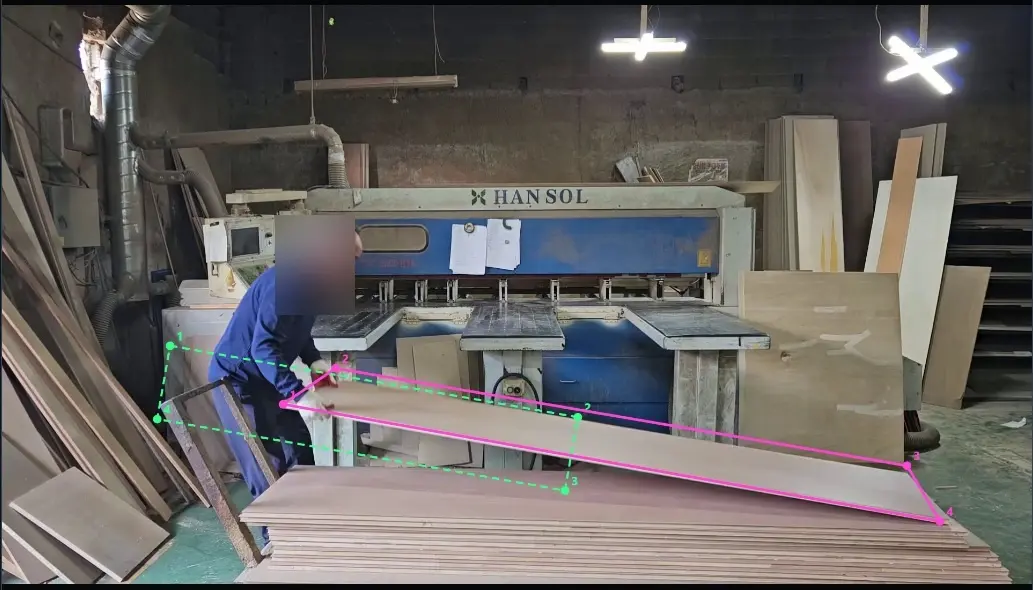
An experimental model combining video and pose information with IMU signals to analyze work motion. IMU-only, video/pose-only, and combined models are compared to evaluate sensor fusion.
In-house domain-specific multimodal model · Experimental validationField video + IMU signals · About 14 seconds each
Faces anonymized · Candidate IMU signal comparison · Not a fusion-model inference recording.
02 / HK SEYMATURBINO R&D
Connect field evidence, expert judgments, and work procedures as structured Skill Records.
Powered by HK-SkillLex · Python Library / API
24-second interface demo using sample data · Not a production screen or a claim of validated performance.
03 / PACIOLI R&D
Structure items, specifications, quantities, and delivery dates from drawings and purchase orders, then connect them to BOMs, order status, and archives.
24-second interface demo using sample data · Not a production screen or a claim of validated performance.
04 / EULER / ISAAC SIM R&D
Isaac Sim research recordings showing panel-family feed trajectories and a dual-robot sequence in a measured equipment model.
Powered by HK Forge · Digital Twin & Simulation Engine
Compare robot feed trajectories for SHORT, MEDIUM, LONG, and WIDE panels. This video replays recorded policy trajectories.
Open video file ↗A measured equipment model shows Robot A feeding a panel, machine transit, and Robot B receiving it. The simulation follows a predefined sequence.
Open video file ↗R&D simulation · Panel-family footage replays recorded trajectories using a simplified vacuum model · Physical equipment and robot performance require separate validation
These technologies are in research and validation. Development progresses through field evidence and evaluation.